UR3e platform

Technologies: Python · ROS 2 · Node-RED · TCP · Docker · colcon · rosdep
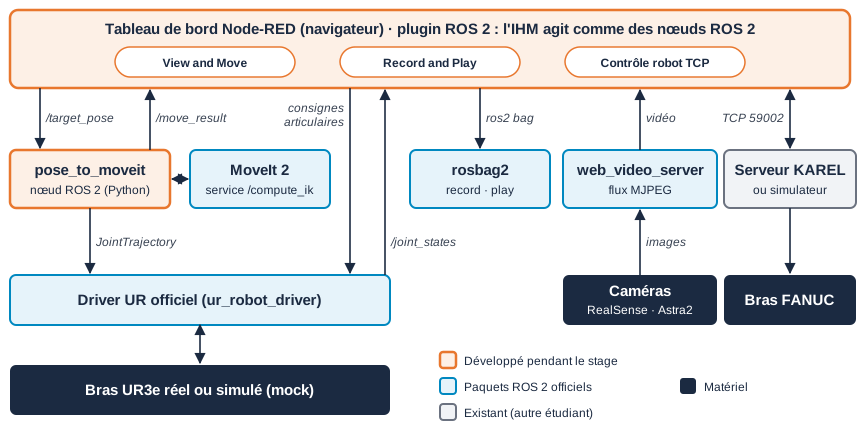
Internship at the IBISC laboratory. The existing components around the arm (force, position and velocity control, cameras) were separate: I brought them together in a single ROS 2 workspace.
The Node-RED interface, built for teaching, lets you:
- control the arm in joint, Cartesian or force mode;
- view the robot’s state and cameras;
- record and replay data.